reduction in real-world time-to-goal versus standard MPPI
Clustering-Embedded MPPI: Avoiding Averaging-Induced Failure and Enabling Efficient Cluster Selection for Dynamic Obstacles
Published and presented at IROS 2026
Supported by
 UW + Amazon Science Hub
This work was supported in part by an Amazon-UW Science Hub Gift Award.
Abstract
With the widespread availability of parallel computing hardware, sampling-based motion planning methods such as Model Predictive Path Integral (MPPI) control have become increasingly powerful for complex nonlinear systems in non-smooth task spaces. However, MPPI can suffer from averaging-induced failure in cluttered environments, where the importance-weighted update averages incompatible rollouts and leads to hesitation or collision.
We propose Clustering-Embedded MPPI (CE-MPPI), a framework that structurally resolves this failure mode by pruning colliding trajectories, clustering feasible rollouts with a collision-derived geometric direction feature, and selecting a single obstacle-aware cluster for the control update. In dynamic scenes, CE-MPPI selects clusters that counter obstacle motion, reducing persistent coupling with moving obstacles.
Method Overview
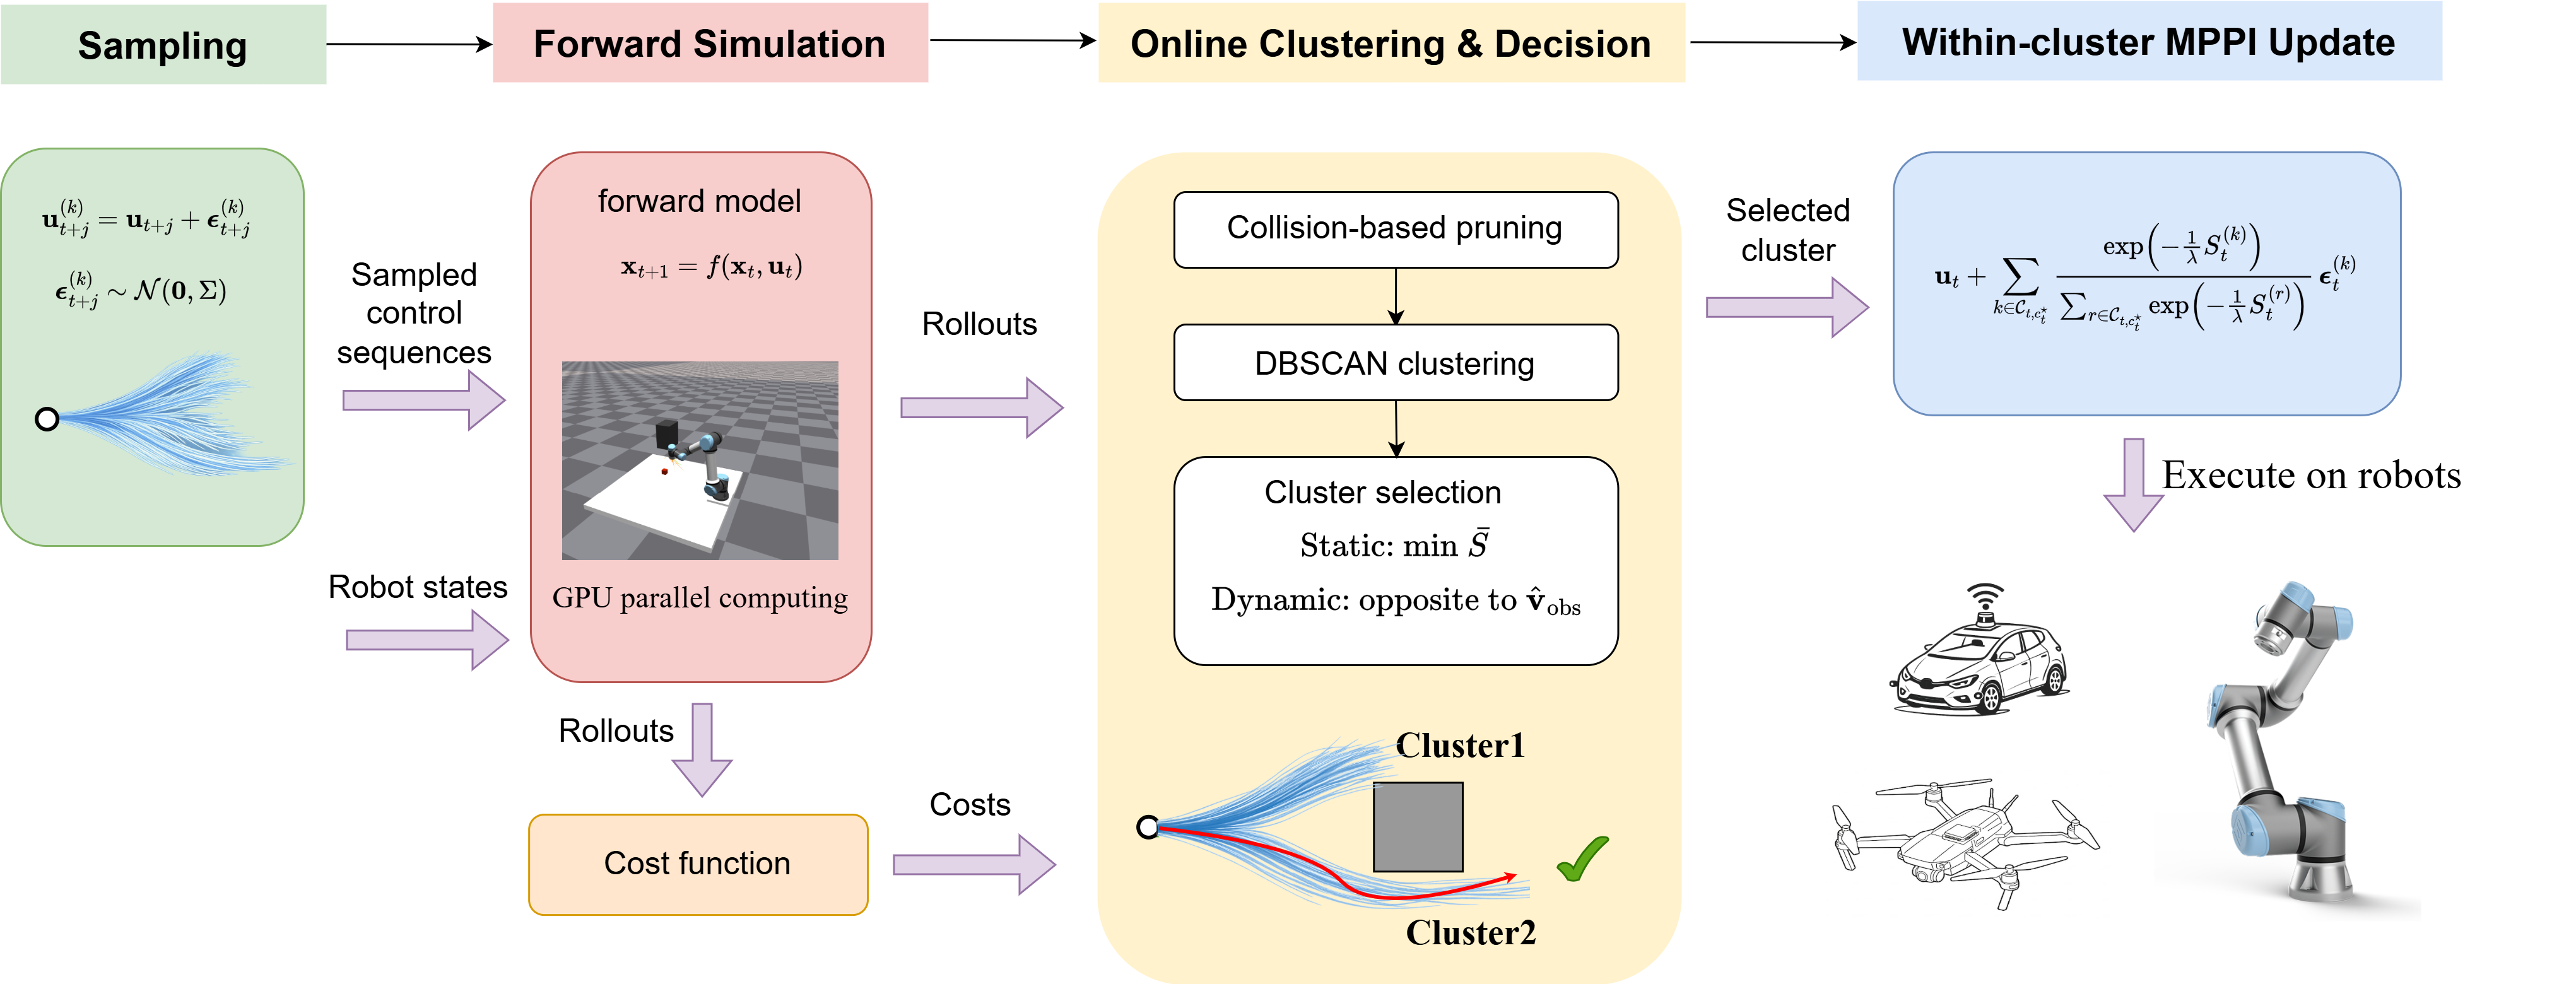
CE-MPPI samples perturbed control sequences and performs parallel forward simulation to obtain trajectory rollouts and costs. Colliding rollouts are pruned, the remaining feasible rollouts are clustered via DBSCAN, and a single cluster is selected (static: minimum average cost; dynamic: motion opposite to the obstacle direction). The MPPI update is then computed using weights normalized over the selected cluster.
Experimental Results
shorter real-world end-effector path
reduction in dynamic-scenario time-to-goal versus CSC-MPPI
shorter simulated path length versus CSC-MPPI
Simulation and Real-World Demonstrations
2-D JAX Simulation
Dynamic-obstacle replanning with clustering-based mode selection. Default playback: 2x.
Real-World UR5e Experiment
High-dimensional obstacle avoidance with CUDA-parallel rollouts in Isaac Gym. Default playback: 2.5x.
Paper
The submitted manuscript is embedded below. If the preview does not load, use the direct paper link in the header.
BibTeX
@inproceedings{liu2026cemppi,
  title = {Clustering-Embedded MPPI:
           Avoiding Averaging-Induced Failure and Enabling Efficient
           Cluster Selection for Dynamic Obstacles},
  author = {Liu, Zidong and Chang, Kaixin and Chen, Xu},
  booktitle = {2026 IEEE/RSJ International Conference on
               Intelligent Robots and Systems (IROS)},
  year = {2026},
  eprint = {2607.06499},
  archivePrefix = {arXiv},
  url = {https://arxiv.org/abs/2607.06499}
}